

Robodogs will assist astronauts at future lunar bases
Chinese engineers propose using robot dogs at lunar bases to handle dangerous and routine tasks, as well as to provide emotional support for the crew. These machines could patrol the area, collect samples, maintain infrastructure, and help people cope with isolation.
Ingenium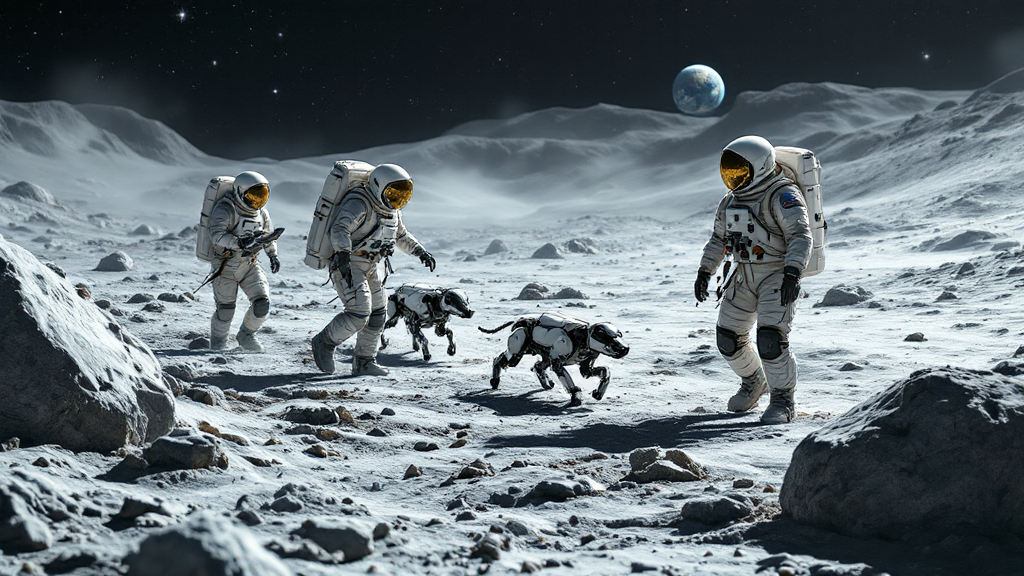
Chinese engineers are exploring the possibility of using robotic dogs on the Moon to support astronauts in their work. Future lunar bases are expected to feature collaboration between humans and various automated machines, including robot dogs. These devices could handle patrols, sample collection, environmental monitoring, and other hazardous or routine tasks, allowing astronauts to focus on more complex operations.
As permanent residents of lunar bases, robotic dogs could assist in surface exploration, resource extraction, shelter construction, and provide companionship during extended periods of isolation. The concept is detailed in a study published in the journal Chinese Space Science and Technology by experts from the China Academy of Space Technology. Unlike previous proposals, this model envisions machines not only as tools for physical tasks but also as potential companions capable of interacting with the crew and reducing psychological stress during long stays far from Earth.
The unique lunar environment—characterized by low gravity, high radiation, extreme temperature fluctuations, abrasive dust, and communication delays with Earth—makes long-term, human-dependent missions particularly challenging and risky. In the proposed system, responsibilities are divided between astronauts and autonomous machines: humans tackle complex problems and respond to unexpected situations, while robots take on heavy, repetitive, and dangerous work.
One scenario involves an expedition where three astronauts are accompanied by two robotic dogs. One crew member operates the four-legged machines, which move ahead to scout the terrain and identify potential hazards. The second astronaut works directly on the surface, collecting samples and performing precise operations. The third coordinates the mission from a sealed mobile module and can take control of other robots if needed.
Four-legged platforms are considered especially effective for navigating the Moon’s rugged terrain, where traversing rocks, ledges, and areas with uneven or loose surfaces is required.
The activities of a future lunar station are divided into four main areas: meeting the crew’s daily needs, conducting scientific experiments, utilizing local resources, and maintaining infrastructure. Machines could be used to search for and extract water ice, process mineral resources, construct buildings from local materials, and prepare lunar lava tubes for use as naturally shielded habitats. Inside living quarters, robots could monitor air quality and temperature, check equipment, clean rooms, care for plants, and even prepare food.
The social role of machines is also being considered. A companion robot could interact with crew members and provide emotional support, helping them cope with the psychological challenges of prolonged isolation.
To ensure effective coordination between humans and robots, a four-level architecture is proposed, encompassing environmental perception, decision-making, action planning, and direct task execution. The system allows for four levels of human involvement—from direct control to fully autonomous operation, where the robot consults a human only in exceptional situations.
China plans to build its first lunar base by 2035. This concept is intended for integration into the International Lunar Research Station (ILRS). According to published plans, the initial station near the Moon’s south pole should be established by 2035, with significant expansion of lunar infrastructure around the orbital station planned by 2045.